I am a final-year M.S. student in Computer Science at
Brown University, advised by
George Konidaris,
Daniel Ritchie, and
Thomas Serre. My research focuses on world models, generative modeling,
and embodied intelligence, with an emphasis on learning representations of the physical
world for planning and decision-making.
I'm currently visiting the
Kempner Institute
at Harvard University, hosted by
Qianqian Wang.
Previously, I conducted research at the National University of
Singapore (NUS). I earned my
B.S. in Computer Science from Fort Hays State University
(FHSU).
I usually go by Lyfey. Coincidentally, my initials are
“CV”—quite fitting for someone working on
computer vision!
I'm seeking PhD opportunities for Fall 2027 in machine
learning, computer vision, and robotics. Please feel free to reach
out!
News
Oct 09, 2026.
Excited to head to Texas next month for the CoRL 2026
Workshop on Do Robots Need World Models?
Looking forward to the discussions by Vincent Sitzmann, Chelsea Finn, and Yunzhu Li. Howdy Texas! 🤠
Sep 09, 2026.
Began visiting the
Kempner Institute
at Harvard University during the final year of my M.S.
Thanks to Brown and
Qianqian Wang
for the opportunity!
Jul 06, 2026.
Started my master's thesis on
Learning World Models for Robotics with
George Konidaris.
May 26, 2026.
Received NSF-supported funding for summer research. Special thanks to
Thomas Serre!
Apr 20, 2026.
Presented
Geodesic Interpolation with Diffusion and Flow
Models
at Brown's Visual Computing Seminar. Thanks to
Daniel Ritchie
and
James Tompkin
for hosting!
Sep 04, 2025.
Started my M.S. in Computer Science at
Brown University.
Publications
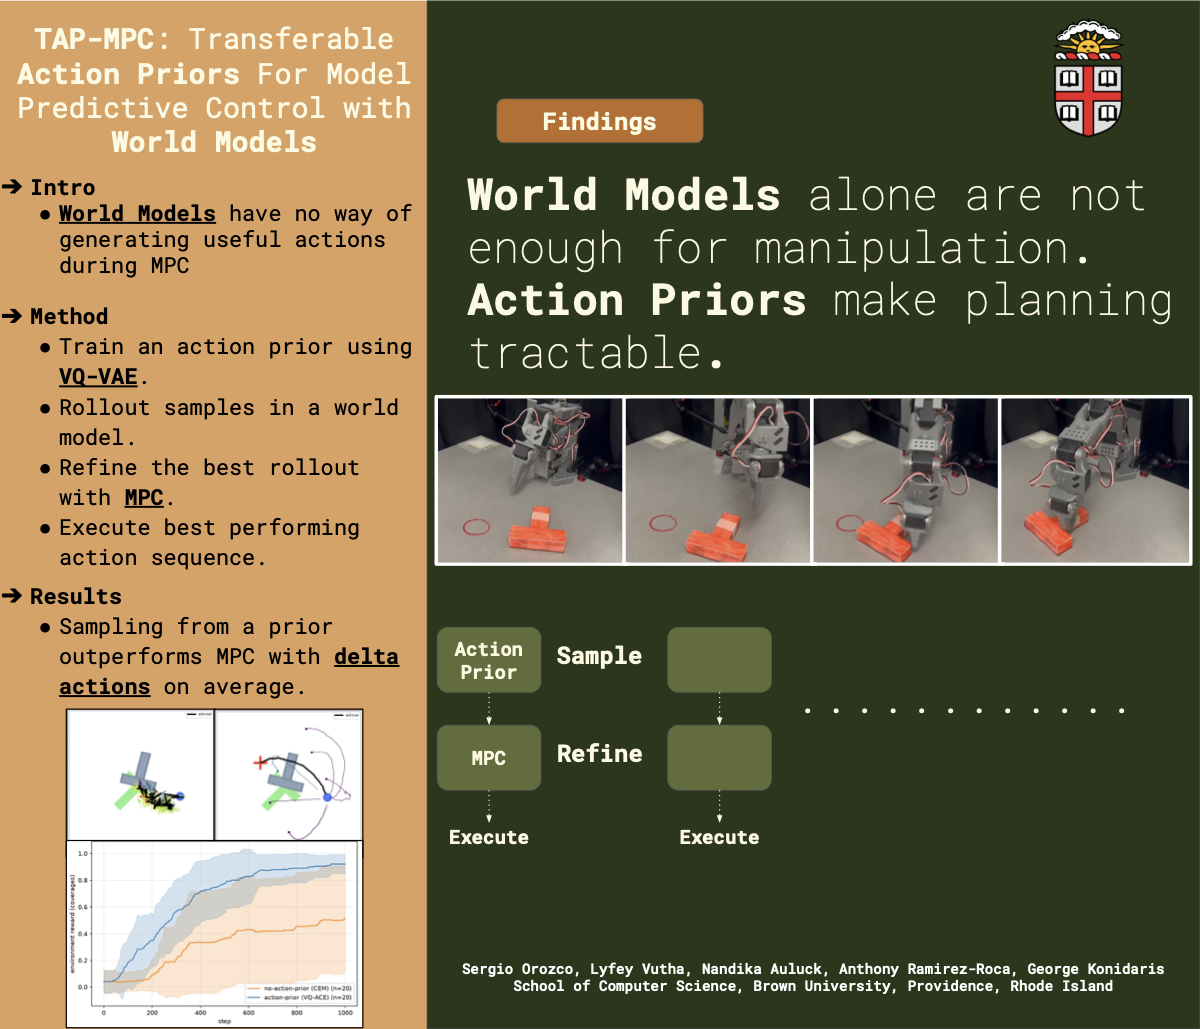
TAP-MPC: Transferable Action Priors for Model Predictive
Control with World Models
Sergio Orozco, Chealyfey Vutha, Nandika
Auluck, Anthony Ramirez-Roca, and George Konidaris
We train an action prior with a VQ-VAE, roll out its samples
in a world model, and refine the best rollout with MPC, making
planning tractable for robotic manipulation.
Chealyfey Vutha, Jorge Chang, Bastien Le Lan,
Victor Boutin, and Thomas Serre
Under Submission
We use Joint Energy-Based Models (JEMs) to interpolate between
discriminative and generative training within a fixed
architecture, and show that human alignment is maximized at
intermediate points along this continuum rather than at either
extreme.
Geodesic Interpolation for Diffusion and Flow Models
Chealyfey Vutha, Zheyu Shi, Yuqiao Guan, and
Daniel Ritchie
Under Submission
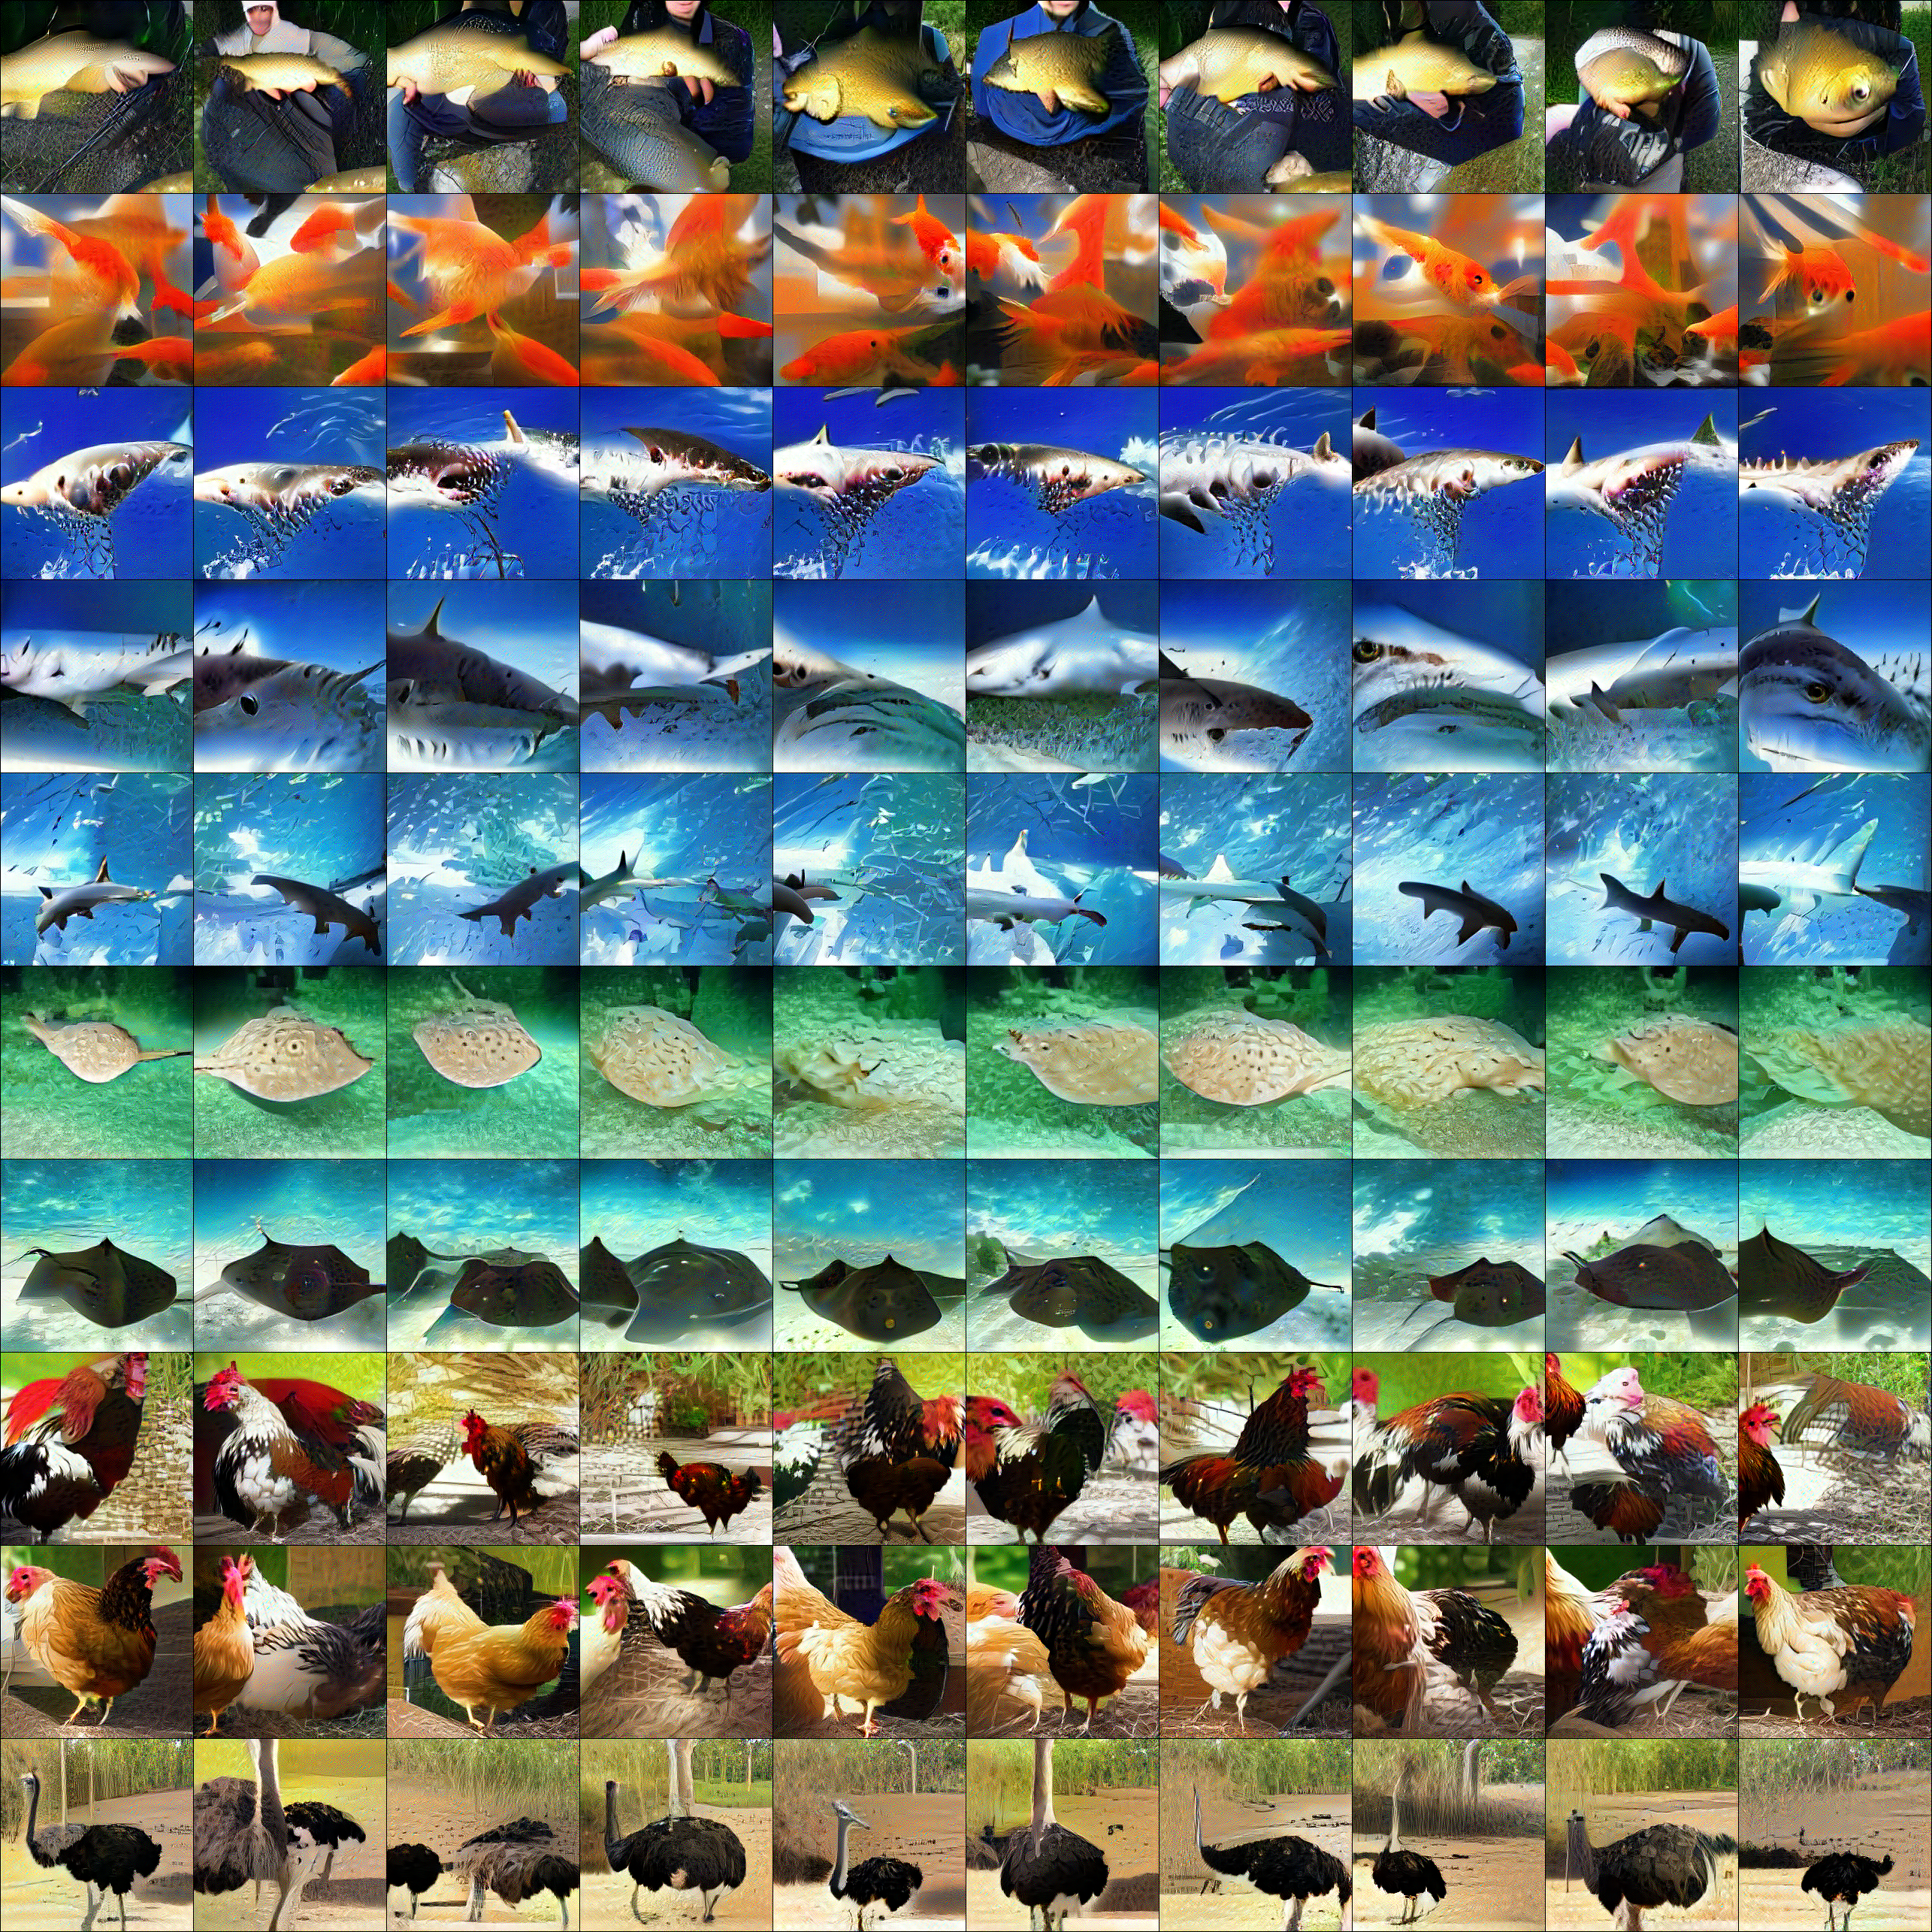
We study interpolation in diffusion and flow models by
following smooth paths, which enables smoother and more
semantically consistent transitions between generated images.
Jan 2025 – Aug 2025— AI
Engineer, Ministry of Post and Telecommunications (MPTC).
Led the development of the speech-to-speech translation
feature for TranslateKH, Cambodia's national translation
application.
Jul 2023 – Dec 2024—
Student Researcher, National University of Singapore (NUS).
Co-developed a research proposal for Heritage Plate, a
storytelling recipe application, securing a $5,000 grant from
the Asian Undergraduate Symposium at NUS.